Code Owns the Simulation, Jev Owns the Evaluation
L1 core-mechanism diagnostic. Clones actual environments, executes branches, and calls the existing provider interface. The local run uses an explicitly lexical diagnostic provider, not real Jev or a reproduction of ALFWorld success rates.
Paper information
| Field | Details |
|---|---|
| Paper | arXiv 2610.01834 |
| Organization | The Chinese University of Hong Kong; first author Yaodong Yang |
| First public release | 2026-10-01 (arXiv v1) |
| Authors' code | No public author repository was found during the 2026-10-04 full-text review. |
| Adapter | jev-lookahead, Python mechanism API rather than a reproduce CLI adapter |
| Local reproduction code | src/auto_research/system_one/lookahead.py |
Original paper
Motivation and method
Executable code simulates each action's successor state; Jev only compares the progress afforded by actions. In addition to the action and next observation, the evaluator receives newly available actions after execution, addressing the difficulty of inferring long-term reachability from semantic action scores alone.
flowchart LR
  S[Current real environment] --> F[Clone once per legal action]
  F --> E[Execute one step per independent copy]
  E --> O[Next observation and newly legal actions]
  O --> J[Structured Jev action scoring]
  J --> C[Return selected action]
  C --> R[Caller executes in real environment]
Key figure from the paper
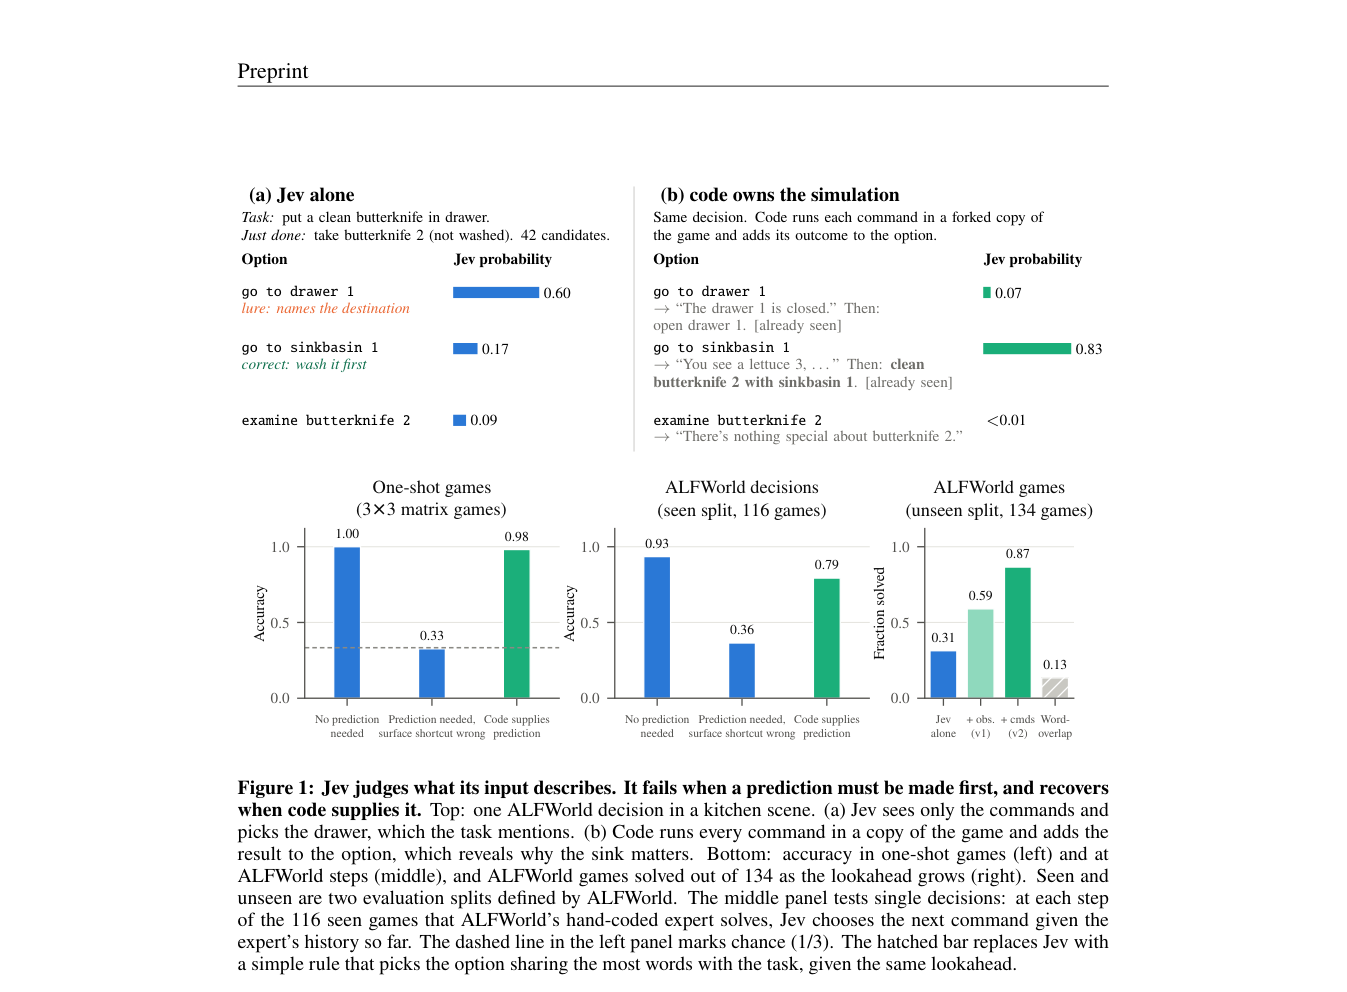
Figure 1: Method overview and key components. From the original paper; copyright remains with the authors.
Core equations
For action \(a\), \(s'_a=\operatorname{step}(\operatorname{clone}(s),a)\) and \(\Delta A_a=A(s'_a)\setminus A(s)\). The decision maker sees only \(a,o(s'_a),\Delta A_a\) and public task history, not simulator reward, gold plans, or success labels.
Paper results
On 134 unseen ALFWorld tasks, the paper reports 42 raw successes, 79 with the next observation, and 116 with newly available actions as well (about 87%). Robot skill selection succeeds in 22/40 trials versus 3/40 for a handwritten selector; the direct raw-torque route succeeds in 0/20. Results across tasks are not directly comparable. No production online A/B test is reported.
Local reproduction
Run PYTHONPATH=src python scripts/run_oct04_seven_papers.py.
simulate_options(environment)clones independently per action, rejectsfork()returning the original object, and does not change real state.choose_with_lookahead(environment, provider, task=..., observation=...)reuses System OneChoiceQuestionandSystemOneRequest, verifies a legal candidate, and does not execute the real action itself.- The environment provides
fork/admissible_commands/step, andstepreturns only an observable string. The caller must isolate deep state, RNG, and external resources; different object identities do not guarantee isolation.
The three-seed artifact logs two simulated branches per run, unchanged real state, and the selected action. The lexical provider is a declared test double, not a source of capability success rates.
Reproduction boundaries
No real Jev checkpoint or hosted API, ALFWorld, or robotics environment was run. No new CUDA path, GPU validation, or evolve improvement is claimed. See the cross-entry in the System One method catalog.