SayCan: Plan with language relevance and executable affordances
Deterministic skill and affordance mini-suite, not physical robot control.
Paper information
| Field | Details |
|---|---|
| Paper | Paper or original source |
| Institution | Robotics at Google / Everyday Robots. |
| First public release | 2022-04-04 |
| Author code | Simulated tabletop implementation. |
| Local adapter or method key | saycan |
| Local reproduction code | src/auto_research/agent_research/ |
Paper method and evidence
Score each pretrained skill by language relevance and value-function affordance. Execute the best product and append the action to context before replanning.
flowchart LR
  A[Enumerate skills] --> B[Multiply language relevance by affordance]
  B[Multiply language relevance by affordance] --> C[Execute and replan]
Original paper figure
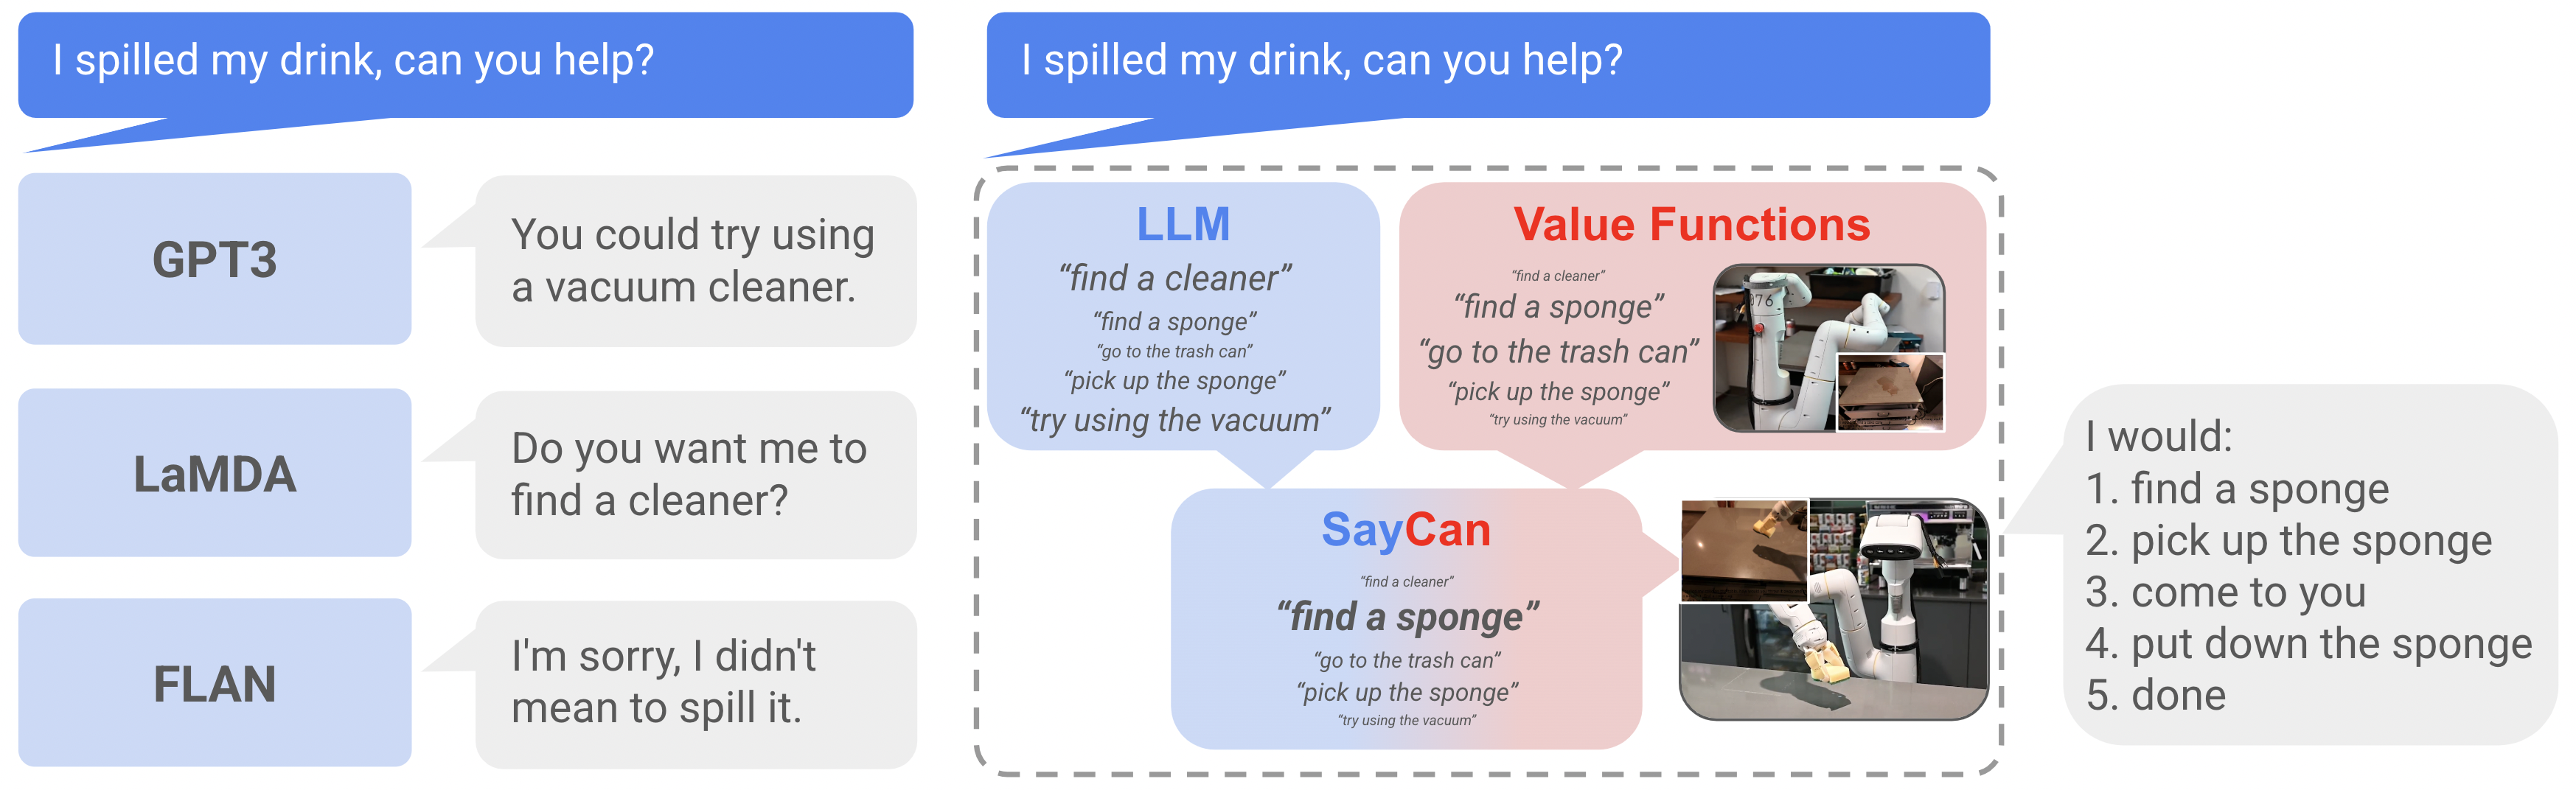
Figure shows language and affordance combination. From the original paper; copyright remains with the authors.
Core equation
\[
\pi(s\mid i,h,e)\propto
p_{\mathrm{LM}}(s\mid i,h)\,
p_{\mathrm{aff}}(\mathrm{success}\mid s,e).
\]
Reported results
On 101 physical-robot tasks, PaLM-SayCan scores 84% planning and 74% execution success; FLAN-SayCan 70% and 61%. Not production A/B.
Local reproduction
PlanBench mini, 120 episodes, seed 42: baseline/SayCan joint success 1.0000/1.0000, mean cost 64.5000/3.3750, affordance checks 0/1350, infeasible filtered 0/790.
auto-research agent-eval --method saycan --benchmark planbench-mini \
  --episodes 120 --memory-size 24 --seed 42
Stable metrics. Deterministic executable skills, no vision, control policy or value-function training.